BoT-SORT Adds Camera-Aware Matching
BoT-SORT upgrades classic tracking with camera-motion correction and better box fusion, so identities survive panning cameras and shaky video.
Why Does This Exist?
Plain SORT assumes a still camera. When the camera pans, every box shifts together and motion prediction points at empty ground. Identities shatter even though nothing was occluded.
BoT-SORT estimates that global camera shift first and removes it before matching. It builds on multi-object tracking, keeps the Kalman core of SORT, and keeps the appearance help of DeepSORT while fixing the camera blind spot.
Think of It Like This
Steadying a tray before sorting cups
You carry a tray of labelled cups across a moving bus. Before checking which cup moved, you first steady the whole tray against the bus sway.
It fails when every cup looks the same and the bus lurches hard. Steadying helps, but identical cups still swap when the jolt is bigger than their spacing.
How It Actually Works
Let be the predicted box and the detected box, where comes from the Kalman forecast and comes from the detector. After camera compensation, overlap is and appearance cosine is . The fused cost is , where equal weights balance motion and looks.
Worked example
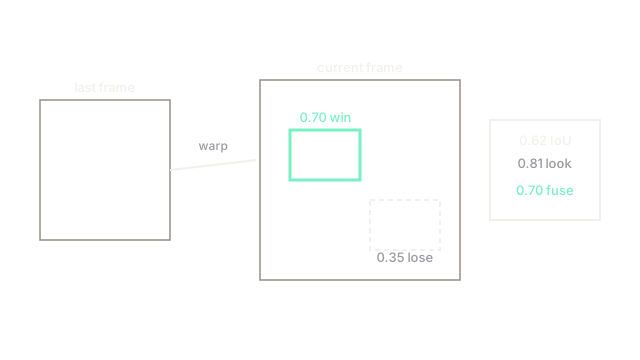
Plug the fixture numbers: , rounded to 0.70 in the diagram. A rival pair scores with , giving . The 0.70 pair wins the Hungarian match and the 0.35 pair stays free. Camera correction moved IoU from 0.20 to 0.62 before fusion, which is the whole gain.
Watch Out For
Trusting compensation during fast rotation
Affine camera estimates fail on fast rotation and zoom, warping boxes to the wrong streets. The symptom is mass mismatches on turning cameras. Gate the warp by its inlier count and fall back to plain IoU when inliers drop under threshold.
The Quick Version
- BoT-SORT removes global camera motion before Kalman prediction and matching.
- Fusion turns 0.62 and 0.81 into a 0.70 match.
- The rival 0.35 pair loses, so identity sticks through the pan.
- Camera warp needs enough inliers or it hurts more than it helps.
- It keeps SORT speed while borrowing DeepSORT appearance strength.